I’m a software architect and robotics engineer with a physics background and a long-running interest in how software becomes motion.
My work ranges from 5-axis aerospace CNC systems, industrial 3D printers, embedded access-control hardware, military flight simulation, and PyTorch/OpenUSD robotics simulation, to large enterprise EDI medical billing systems.
I like working across the boundaries: firmware and electronics, control and mechanics, simulation and visualization, domain models and distributed software. I’ve led engineering organizations, and I still want to understand what happens at the pin, the machine, and the line of code.
Outside client work, I build autonomous multirotors, work on a CNC-retrofitted Bridgeport mill, and develop simulation systems. PipeMajor brings another interest into that mix: bagpipes, physical instrument simulation, and interactive music.
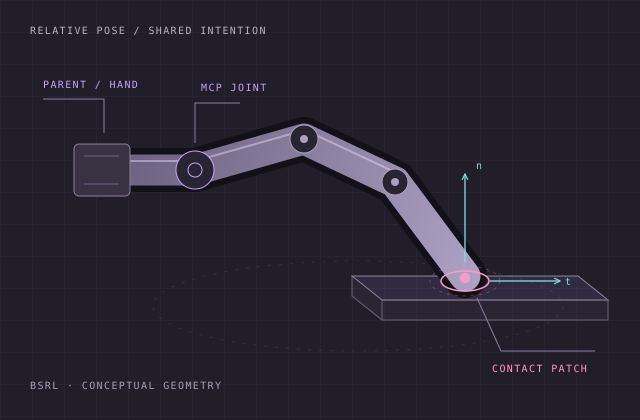
My current research direction is BodySyntonic: exploring a shared representation for perception, intention, and prediction in Physical AI. It grows out of my work with APT and VisualAPT, where motion is described through relationships with geometry.
A few things I keep coming back to.
- 01
Understand the physical system.
The real machine is the final test of the model.
- 02
Give the domain a clear structure.
Explicit identity, ownership, and interfaces make complex systems easier to reason about.
- 03
Stay close to the work.
Architecture and leadership are stronger when connected to implementation.